Scale-inspired programmable robotic structures
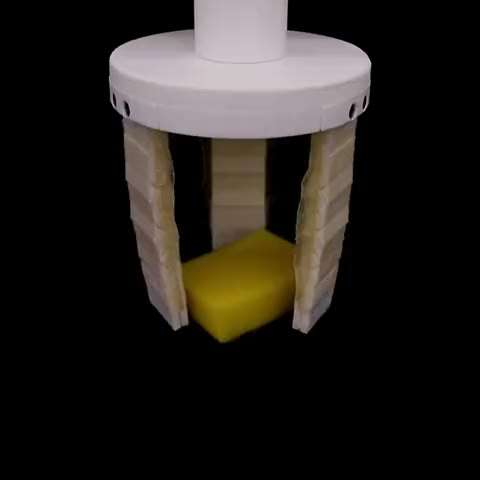
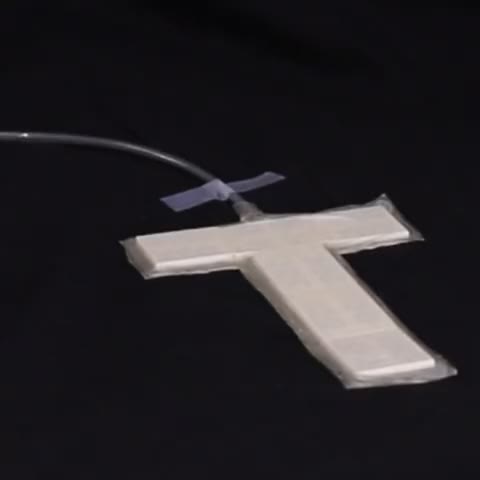
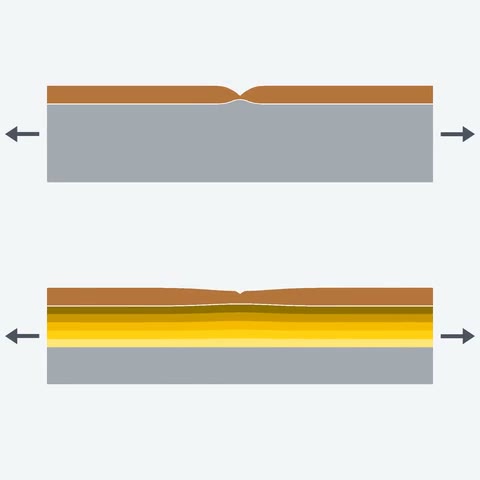
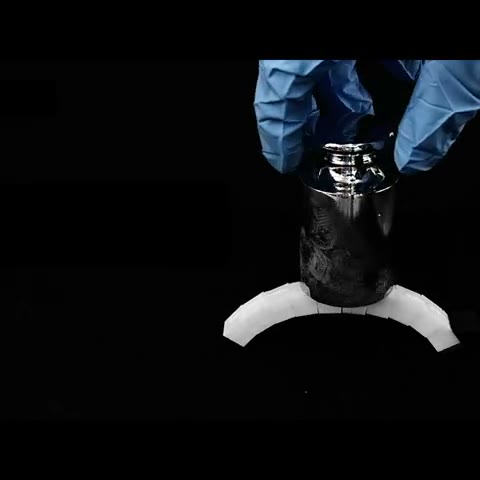
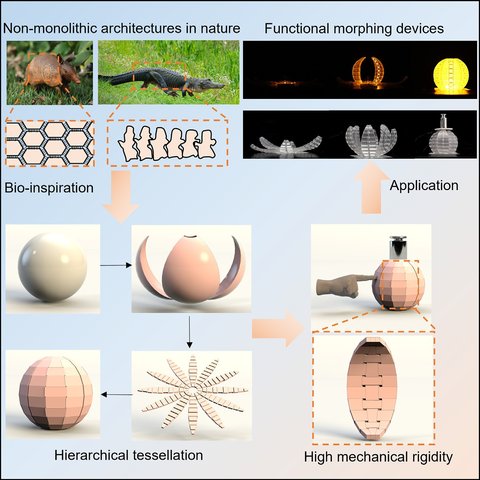
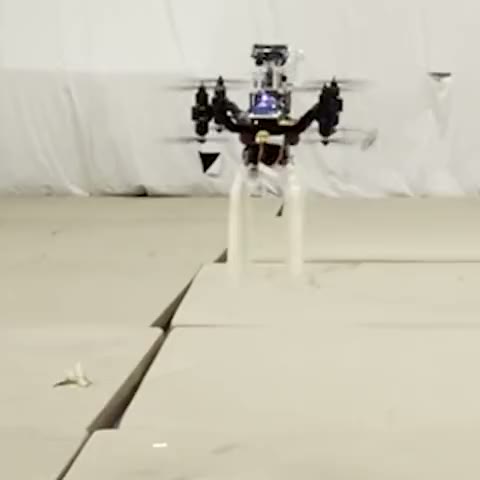
A structure inspired by fish and pangolin scales takes a designed shape as it stiffens under vacuum, used in an amphibious robot and drone landing gear.
Science Robotics 9, eadl0307 (2024)
Tianyu ChenResearch Associate, Bristol Robotics Laboratory
At the Bristol Robotics Laboratory, University of Bristol, I work in the VIVO Hub for Enhanced Independent Living on electrostatic actuators, a lightweight replacement for the bulky motors and pneumatic systems in exosuits.
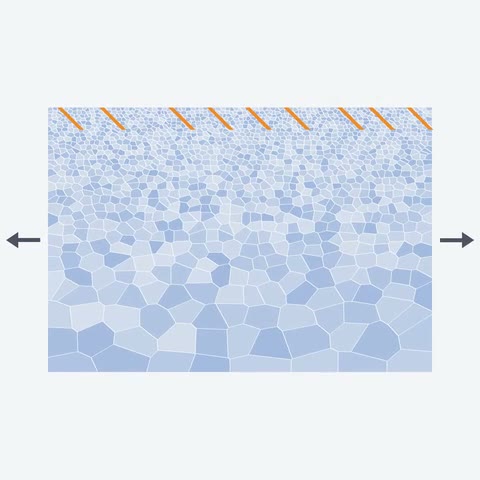
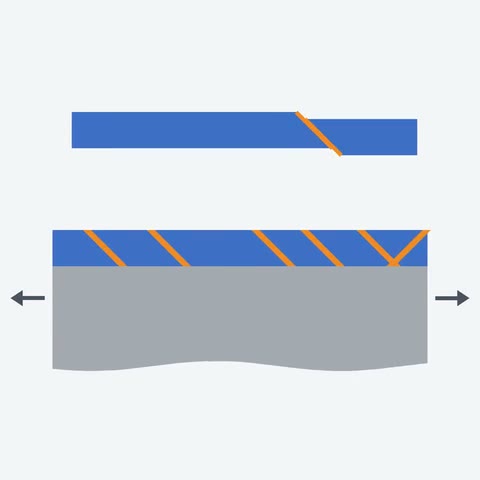
Previously, I did my PhD at Nanyang Technological University in Prof. Yifan Wang’s Robotic Materials Group, where I developed a scale-inspired layered structure whose inversely designed surface patterns let it morph into a target shape and change its stiffness at the same time. From it, I built an amphibious robot and a drone landing gear. Before that, I used finite element models to study how thin films and nanostructured metals deform.
A structure inspired by fish and pangolin scales takes a designed shape as it stiffens under vacuum, used in an amphibious robot and drone landing gear.
Science Robotics 9, eadl0307 (2024)
A data-driven controller, inspired by how opposing muscles tense together, learns in minutes to control the motion and stiffness of robots driven by opposing actuators.
Science Advances 12, eaeg3346 (2026)
Geometric analysis and simulations give design rules for a scale structure: friction above a threshold hinders morphing, and reshaping the scales’ surface eases the trade-off between morphing and stiffening.
International Journal of Mechanical Sciences 284, 109699 (2024)
A computational model of gradient nanograined copper shows that its coarse-grained core makes shear bands form early and multiply at the surface, explaining its ductility.
Nanomaterials 11, 2468 (2021)
Simulations show that a metal substrate makes a thin metallic glass film form many shear bands instead of one, which raises its tensile ductility.
International Journal of Solids and Structures 195, 1–12 (2020)
Simulations show that a substrate whose grains coarsen with depth can let a thin film stretch further before necking than a uniform coarse-grained substrate does.
International Journal of Solids and Structures 166, 124–134 (2019)
Co-authored
Bistable joints modeled on natural sutures let metamaterials built from particles morph and then hold their shape under load without continuous actuation.
Advanced Functional Materials 36, e78343 (2026)
Co-authored
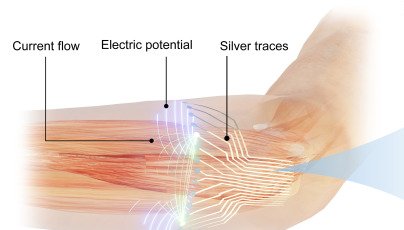
A thin, soft impedance sensor that conforms to skin reads the contractions of several deep muscles, for gesture recognition, force prediction, human-robot collaboration and exoskeleton control.
Science Advances 11, eadv3359 (2025)
Co-authored
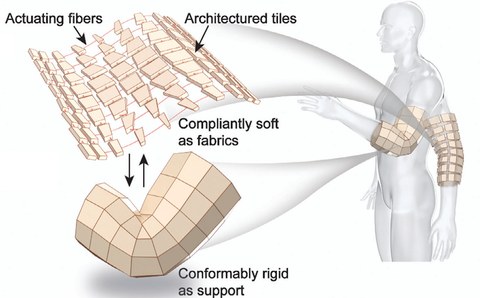
Rigid tiles linked by actuated fibers form fabrics that switch from soft to stiff around the body, for exosuits and body armor.
Advanced Materials 36, 2404502 (2024)
Co-authored
A design method divides a curved 3D surface into rigid particles laid out flat, which tendons pull into that shape with tunable stiffness.
Matter 7, 603–619 (2024)
Oct 2026
Sep 2026
机器人大讲堂, on Tencent News · on Muscle coactivation-inspired stiffness-driven control
Jul 2025
机器人大讲堂 · on Muscle impedance sensors for human-machine interfaces (co-authored)
Sep 2024
ASME, Mechanical Engineering · on Active fabrics with controllable stiffness (co-authored) and Scale-inspired programmable robotic structures
Jul 2024
Jul 2024
Jul 2024
联合早报 (Lianhe Zaobao) · on Active fabrics with controllable stiffness (co-authored) and Scale-inspired programmable robotic structures
Jul 2024
Interesting Engineering · on Active fabrics with controllable stiffness (co-authored) and Scale-inspired programmable robotic structures
Jul 2024
机器人大讲堂 · on Scale-inspired programmable robotic structures
Jul 2024
VoxelMatters · on Active fabrics with controllable stiffness (co-authored)
Jul 2024
Engineering.com · on Active fabrics with controllable stiffness (co-authored) and Scale-inspired programmable robotic structures
Jul 2024
NTU Singapore press release · on Active fabrics with controllable stiffness (co-authored) and Scale-inspired programmable robotic structures
Also on EurekAlert!, TechXplore and Lab Manager
Jul 2024
高分子科学前沿, on Tencent News · on Scale-inspired programmable robotic structures
Dec 2023
爱科学, from 科学网 · on Hierarchical tessellation for morphing matter (co-authored)
Nov 2023
Advanced Science News · on High-efficiency single-droplet energy harvester for self-sustainable environmental intelligent networks (co-authored)
Jan 2023
Medical Dialogues · on A dual-responsive artificial skin for tactile and touchless interfaces (co-authored)
Jan 2023
GEN, Genetic Engineering & Biotechnology News · on A dual-responsive artificial skin for tactile and touchless interfaces (co-authored)
Jan 2023
Jan 2023
Jan 2023
Wiley press release, on EurekAlert! · on A dual-responsive artificial skin for tactile and touchless interfaces (co-authored)
Also on TechXplore